

Engine Remote Control, Shaft Power Measurement & Computer Indicator Systems
Master marine propulsion control: bridge-ECR changeover, strain gauge torsionmeter shaft power, slow turning valve, and computer indicator diagram analysis.
1. Propulsion Control System Architecture: Alphatronic, Telegraph Integration & Station Hierarchy
Modern marine propulsion plants utilize integrated digital propulsion control systems that coordinate engine starting sequences, speed governing, reversing, load programming, and safety interlocks across multiple control stations. The industry-standard system for MAN B&W two-stroke engines is the Alphatronic 2000 Propulsion Control System, while competing systems include the Kongsberg AutoChief, Nabtesco M-800, and WinGD UNIC.
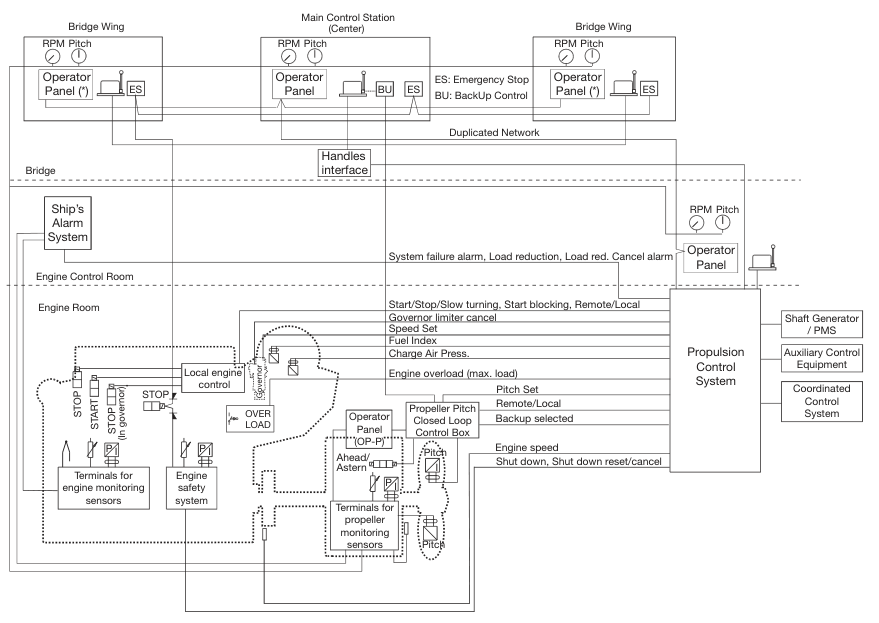
Functional Architecture of the Propulsion Control System
The propulsion control system performs the following integrated functions automatically when a speed or direction command is issued:
- Starting Sequence Programmer: Upon receiving a START command from any station, the system:
- Verifies all safety interlocks are satisfied (turning gear disengaged, lube oil pressure normal, reversing complete, starting air pressure adequate).
- Executes the slow-turning valve pre-start rotation (if enabled and engine has been stopped > 30 minutes).
- Opens the main starting air valve, admitting 30-bar air through the pilot distributor to roll the engine.
- At minimum firing speed (~12 to 18 RPM for two-stroke), the system engages fuel, closes the starting air valve, and transfers speed command to the governor.
- Speed Program & Load-Up Ramp: The governor receives the bridge speed lever position as a setpoint. A programmable load-up ramp prevents instantaneous acceleration from Dead Slow to Full Ahead, instead linearly ramping the fuel index over 15 to 45 minutes to protect against thermal shock. The smoke limiter (scavenge air pressure fuel index limit) further restricts fuel during transient acceleration.
- Reversing Command: When direction is changed (Ahead → Astern or vice versa), the system automatically: stops fuel → decelerates engine to zero RPM → commands reversing servomotor or electronic reversing → confirms direction end-stop switches → re-initiates starting air sequence in the new direction.
- Telegraph Integration: The electric engine order telegraph (EOT) is directly interfaced with the propulsion control system. Each telegraph notch (Dead Slow, Slow, Half, Full) is mapped to a calibrated engine RPM setpoint stored in the system memory.
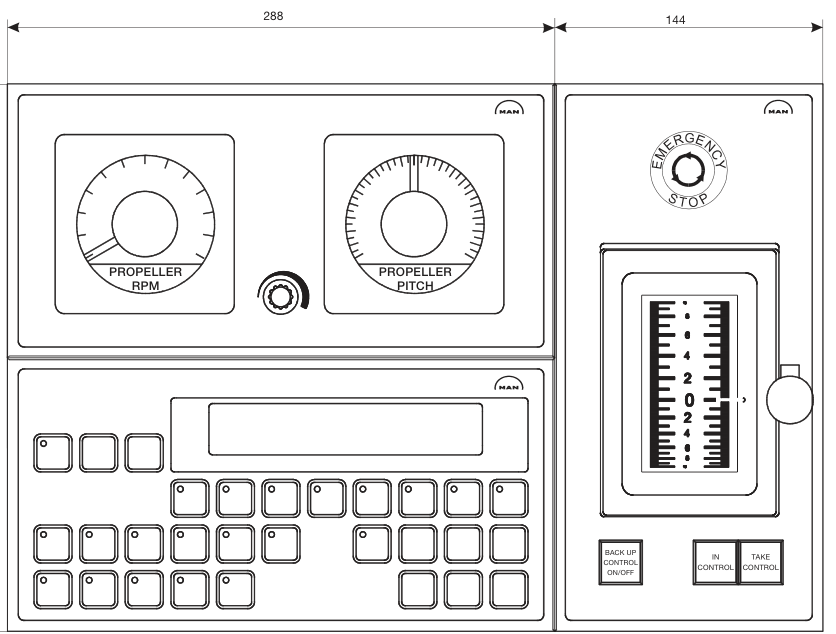
The Three Control Station Hierarchy
| Control Station | Location & Authority | Activation Method | Operational Capabilities |
|---|---|---|---|
| Navigation Bridge | Wheelhouse; highest remote authority during normal sea passage and UMS. | ECR rotary selector switch set to "BRIDGE". Mutual telegraph acknowledgement. | Full speed control, reversing, starting/stopping via combined lever. Automated start programmer handles all sequencing. Bridge slowdown override available. |
| Engine Control Room (ECR) | Soundproof ECR adjacent to engine room; primary engineering control. | ECR selector switch set to "ECR". Bridge is notified; telegraph synchronization verified. | Full manual speed control via maneuvering console. Direct governor setpoint override. Access to all diagnostic data, alarm management, and safety system testing. |
| Local Emergency Stand | On the engine itself, at the fuel pump gallery or camshaft platform. | Manual fuel lever pulled out of REMOTE detent into direct mechanical linkage. | Direct mechanical fuel rack control. Manual starting air valve operation. Manual reversing lever. No electronic automation — pure mechanical control. |
2. Control Changeover Protocols & Emergency Local Takeover
Transferring propulsion control authority between stations is a critical operational procedure that must be executed with disciplined communication, systematic verification, and mutual acknowledgement. Errors during changeover have historically caused grounding, collision, and major engine damage.
Bridge-to-ECR Changeover (Standard)
- The ECR watchkeeper confirms all automation systems are healthy, no active machinery alarms exist, and the engine is running at a safe steady speed.
- The ECR engineer calls the bridge: "ECR requests control. Please acknowledge."
- The bridge officer moves the bridge telegraph lever to match the current running speed order.
- The ECR engineer turns the Master Control Selector Switch from "BRIDGE" to "ECR". The bridge "CONTROL ACTIVE" lamp extinguishes; the ECR "CONTROL ACTIVE" lamp illuminates.
- The ECR engineer rings the telegraph to match the running order; the bridge acknowledges. Both parties log the exact timestamp.
ECR-to-Bridge Changeover (Standard)
- Verify two generators are running in parallel, steering gear dual power units are active, auxiliary blowers are in AUTO, and all pre-departure safety checks are complete.
- The ECR engineer selects "BRIDGE" on the master control switch.
- The bridge officer accepts control by acknowledging the telegraph and pressing the "ACCEPT" pushbutton.
- Verify the green "BRIDGE CONTROL" status lamp illuminates on both consoles.
Danger: Emergency Local Takeover Protocol
If electronic control systems suffer a total failure (power supply failure, control bus communication crash, governor actuator seizure, or ECR fire), the engine can be operated from the Local Emergency Stand:
- Takeover is permitted at any time — running or stopped. The local engineer manually pulls the fuel rack control lever out of the "REMOTE" detent slot into the direct mechanical linkage position.
- The instant the lever is extracted from REMOTE, the electronic governor and all automated start/stop sequences are disconnected. The fuel rack is now under 100% direct human mechanical control.
- If the engine is running, it continues at its current speed, controlled entirely by the local engineer's hand position on the fuel lever. The engineer must carefully trim fuel by hand while monitoring tachometer and exhaust temperatures.
- Verify that the independent overspeed protection trip mechanism remains armed and functional even in local mode.
- The bridge retains an independent Emergency Stop pushbutton that directly vents fuel control air regardless of control station position.
Critical Rule: Return to remote electronic control is only permitted with the engine completely stopped. This is because re-engaging the electronic governor onto a running engine could cause a sudden uncontrolled speed step if the governor actuator position does not exactly match the current fuel rack index.
The Slow-Turning Air Valve: Anti-Hydraulic-Lock Protection
When a main engine has been idle for more than 30 minutes, water from cracked cooling passages or liquid fuel from dripping injectors may have accumulated on piston crowns. SOLAS and engine manufacturers mandate a Slow-Turning Valve that automatically activates before the full starting air sequence:
- Operation: When a START command is issued and the engine has been stationary beyond the pre-set timer threshold (30 minutes), the propulsion control system diverts starting air through a pressure-reducing bypass valve, admitting air at reduced pressure (typically 8 to 12 bar instead of 30 bar).
- Slow Rotation: The engine crawls at 1 to 3 RPM for one complete revolution. The reduced air pressure produces limited cranking torque — enough to detect a hydraulic obstruction (liquid column in the combustion chamber) by causing the engine to stall or the shaft to jolt, but insufficient to cause destructive connecting rod bending.
- Automatic Progression: If the slow-turn revolution completes without obstruction, the system automatically progresses to full 30-bar starting air pressure and the normal starting sequence.
- Fault Detection: If the engine fails to complete one revolution within the prescribed time (typically 15 to 20 seconds), the system aborts the start and sounds an alarm: "SLOW TURNING INCOMPLETE — CHECK FOR HYDRAULIC LOCK." The engineer must then open indicator cocks and investigate.
3. Shaft Power Measurement: Strain-Gauge Torsionmeters & Wireless Telemetry
The engine's Indicated Power (Pi) is the thermodynamic power developed inside the combustion chamber, computed from indicator card area. The Brake Power (Pb) — also called shaft power or delivered power — is the actual mechanical power transmitted through the intermediate shaft to the propeller, after deducting all frictional losses in bearings, piston rings, crossheads, gear trains, and stern tube seals.
Power Relationships
Where ηmech is the mechanical efficiency of the engine (typically 0.88 to 0.92 for large two-stroke crosshead engines), and Pfriction represents all mechanical friction losses.
It is impractical to measure shaft torque by dynamometer braking at sea. Instead, the shaft torsionmeter measures the minute elastic twist of the rotating intermediate shaft, from which torque and power are derived continuously while underway.
Operating Principle: Elastic Twist & Strain Gauges
When torque is transmitted through a solid cylindrical shaft, the shaft experiences elastic torsional shear deformation. The angle of twist (φ) between two reference cross-sections separated by a gauge length (L) is directly proportional to the applied torque:
Shaft Twist & Torque Relationship
Where:
- T: Applied torque (N·m)
- G: Shear modulus of elasticity of shaft steel (~80 GPa)
- J: Polar second moment of area of the shaft cross-section (= πd4/32 for a solid shaft of diameter d)
- φ: Angle of twist between gauge planes (radians)
- L: Gauge length between measurement planes (meters)
The Wheatstone Full-Bridge Configuration
Four high-precision metallic foil strain gauges are bonded directly onto the polished surface of the intermediate shaft at 45° to the shaft axis (the direction of maximum shear strain). They are electrically connected in a Wheatstone full-bridge circuit:
- Two gauges are oriented at +45° (tension axis); two at −45° (compression axis) during clockwise torque.
- When the shaft twists under torque, the tension gauges increase resistance while the compression gauges decrease resistance. The bridge produces a differential voltage output directly proportional to torsional shear strain.
- Full-bridge arrangement provides maximum sensitivity (4× single gauge), inherent temperature compensation (all gauges experience the same thermal expansion), and rejection of bending strain (bending affects all four gauges equally, canceling in the bridge output).
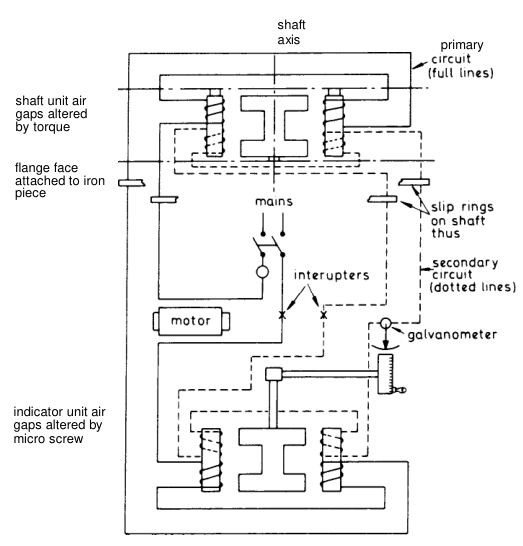
Signal Extraction from the Rotating Shaft
The fundamental challenge of torsionmeters is extracting the low-voltage strain signal from the continuously rotating shaft to stationary processing electronics:
| Method | Technology | Advantages & Limitations |
|---|---|---|
| Carbon Brush Slip Rings | Silver-plated copper slip rings bonded to the shaft; carbon brush contacts feed the DC bridge excitation and extract the millivolt signal. | Simple and inexpensive. However, brush wear produces carbon dust contamination, contact resistance drift, and electrical noise. Requires regular brush and ring maintenance. |
| FM Wireless Telemetry | A miniature battery-powered or inductively powered electronics module bonded to the shaft converts the bridge voltage into a frequency-modulated (FM) radio signal, transmitted by a rotating antenna to a stationary receiver coil. | Zero physical contact, no brush wear, no electrical noise, extremely reliable. Industry standard for modern installations (e.g., Kyma, VAF, Shoyo). |
| Inductive Air-Gap Coupling | A transformer core with a precisely maintained air gap surrounds the shaft. Shaft-mounted coils interact with stationary coils via electromagnetic induction. | Non-contact. Requires precise alignment and stable air gap clearance; affected by shaft axial play. |
Shaft Power Computation
Once torque (T) is measured from the strain gauge signal and shaft RPM (N) is counted from a proximity sensor scanning a toothed wheel:
Brake (Shaft) Power Equation
Where:
- Pb: Brake (shaft) power in Watts
- N: Shaft speed in revolutions per minute (RPM)
- T: Measured shaft torque in Newton-meters (N·m)
4. Digital Indicator Systems: Piezoelectric Transducers & Crank Angle Analysis
Traditional mechanical spring-loaded indicator instruments (Dobbie McInnes, Maihak) physically trace a pressure-volume diagram on a rotating paper drum. While functional below ~120 RPM, mechanical indicators suffer from inertia distortion at medium and high speeds, and their accuracy depends entirely on manual technique.
Modern marine engines utilize computer-based electronic indicator systems (e.g., Kistler KIBOX, Leutert DiCom, PMI system) that provide precise, high-resolution, digitally stored pressure data synchronized to crank angle position, enabling analysis impossible with mechanical drums.
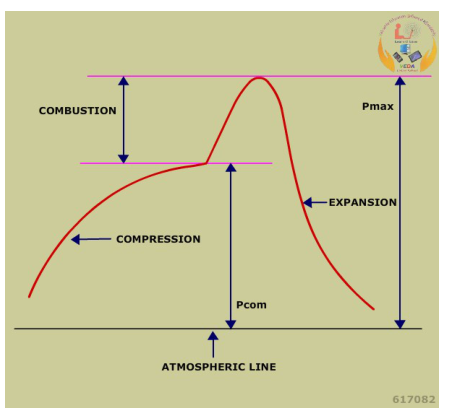
System Components
- Piezoelectric Pressure Transducer:
- A precision piezoelectric quartz crystal sensor threads directly onto the cylinder indicator cock boss (replacing the mechanical indicator).
- Cylinder combustion pressure (0 to 200+ bar) mechanically compresses the quartz crystal, generating a charge signal proportional to instantaneous pressure with a natural frequency response exceeding 100 kHz.
- Unlike piston-type sensors, piezoelectric transducers have no moving mass, eliminating inertia error regardless of engine speed.
- Optical Crank Angle Encoder:
- An optical disc with 360 to 3,600 precisely photo-etched slots is mounted on the crankshaft free end or flywheel.
- An infrared LED and photodetector count pulses, resolving crank angle to 0.1° to 1.0° resolution.
- A single reference slot per revolution provides the Top Dead Centre (TDC) index marker.
- Data Acquisition Processor:
- A ruggedized industrial computer samples the transducer charge output at every crank angle increment, building a complete pressure-angle array for every engine revolution.
- Averages 10 to 100 consecutive cycles to produce statistically smooth diagrams, rejecting cyclic noise.
The Four Fundamental Indicator Card Types
| Card Type | X-Axis | Y-Axis | Primary Engineering Diagnostic Value |
|---|---|---|---|
| Power Card (P-V Diagram) | Cylinder Volume | Pressure | The enclosed area is directly proportional to indicated work per cycle. Mean Indicated Pressure (MIP) = Area / Stroke Length. Indicated Power = MIP × A × L × N × k. |
| Draw Card (P-θ Diagram) | Crank Angle (θ) | Pressure | Reveals injection timing, ignition delay, maximum pressure (Pmax), rate of pressure rise (dP/dθ), and afterburning with exact crank angle referencing. |
| Compression Card | Volume or Angle | Pressure | Taken with fuel cut off (no injection). Pure compression and expansion polytropic curves reveal piston ring tightness, exhaust valve sealing, and true compression ratio. |
| Light Spring Card | Crank Angle | Pressure (expanded low-pressure scale) | Captures the gas exchange process: scavenge port opening/closing, exhaust valve opening/closing timing, turbocharger back-pressure, and scavenge air pressure during the gas exchange period (~100° to 260° ATDC). |
Multi-Cylinder Overlay Analysis
The defining advantage of computer-based indicator systems is their ability to overlay all cylinder pressure traces simultaneously on a single display, each in a distinct color:
- Balanced Cylinders: All traces coincide closely, confirming uniform fuel distribution, identical compression pressures, and equal Pmax values across all units.
- Weak Cylinder Detection: A cylinder with a smaller power card area (lower MIP), reduced Pmax, or delayed injection timing immediately stands out as a thin, displaced trace against its healthy siblings.
- Injection Fault Diagnosis: On the crank angle draw card, the injection point, ignition delay period, rate of pressure rise, and point of maximum pressure are directly measurable in degrees, enabling precise VIT adjustment and injector troubleshooting.
The MC Engine Combustion Pressure Dip — Design, Not Fault
On conventional MAN B&W MC-type (camshaft-controlled) two-stroke engines, the draw card consistently shows a small pressure dip immediately after TDC before the main combustion pressure rise. This characteristic dip is by design:
- MC engines deliberately retard fuel injection timing such that peak firing pressure (Pmax) is limited to approximately 35 to 55 bar below the maximum design pressure (compared to ME electronically controlled engines that optimize for higher Pmax).
- This pressure limiting protects the mechanical crosshead bearing from excessive gas load, as the crosshead bearing has no hydrodynamic rotation (unlike crankpin bearings) and relies solely on squeeze-film lubrication.
- Do not re-advance injection timing to eliminate this dip. Instead, investigate declining engine performance by first checking scavenge air supply, charge air cooler cleanliness, piston ring condition, exhaust valve sealing, and stuffing box integrity.
5. Indicated Power Calculation & Mechanical Efficiency Assessment
The indicated power developed inside each cylinder is computed from the pressure-volume indicator card. Whether taken by a mechanical indicator (spring-type on slow-speed engines) or a piezoelectric computer system, the fundamental calculation method is identical.
Indicated Power Equation (Two-Stroke Engine)
Where:
- Pmi: Mean Indicated Pressure from the power card (bar or Pa)
- A: Piston crown area (m2)
- L: Piston stroke length (m)
- N: Engine speed (RPM)
- n: Number of cylinders
- For two-stroke engines, every revolution is a working stroke (k = 1); for four-stroke, k = 0.5.
Mean Indicated Pressure (MIP / Pmi) from Card Area
For mechanical indicator cards, MIP is determined by measuring the net enclosed area of the power card (using a planimeter or by counting grid squares), then dividing by the diagram stroke length and multiplying by the indicator spring scale factor:
Where the Spring Scale is the calibrated constant of the mechanical indicator spring (e.g., 4 bar/mm for a strong spring used on slow-speed two-stroke engines).
For computer-based systems, MIP is automatically computed by numerical integration (Simpson's rule or trapezoidal integration) of the digital pressure-volume data array.
Mechanical Efficiency Assessment
By simultaneously measuring indicated power (from the indicator system) and brake power (from the shaft torsionmeter), the overall mechanical efficiency of the engine is directly determined:
Typical values: 88% to 92% for large slow-speed two-stroke crosshead engines.
82% to 88% for medium-speed four-stroke trunk piston engines (higher friction from piston skirt side-thrust).
A declining mechanical efficiency trend (tracked weekly in the engine logbook) indicates increasing frictional losses due to bearing wear, piston ring degradation, stuffing box drag, stern tube packing tightness, or propeller shaft misalignment.
6. MEO Class 1 & Class 2 Examination Technical Analyses
Maritime Examiner Oral Assessment Standards
Questions on propulsion control, shaft power measurement, and indicator diagram analysis are central to MEO Class 4, Class 2, and Class 1 oral examinations. Surveyors demand rigorous physical understanding of measurement principles and diagnostic interpretation.
Q1: Explain the step-by-step procedure for performing an emergency local takeover of main engine control when the electronic remote control system has completely failed.
Model Engineering Answer:
When the electronic remote control system fails (loss of PLC communication, governor actuator seizure, or ECR fire):
- Immediately inform the bridge: "Remote control has failed. Taking over engine at the Local Emergency Stand."
- Station yourself at the local maneuvering platform adjacent to the fuel pump gallery.
- Physically pull the fuel rack control lever out of the "REMOTE" detent into the direct mechanical linkage slot. This instantly disconnects the electronic governor and all automated controls.
- If the engine is running, immediately verify tachometer RPM and trim the fuel lever to maintain the current speed. Monitor exhaust temperatures across all cylinders.
- Verify that the independent overspeed trip mechanism is functional (it operates independently of the electronic system).
- Communicate with the bridge by direct telephone or radio. All speed and direction orders must now be executed manually.
- For reversing: manually operate the reversing lever to shift the camshaft (or, on ME engines, manually command the direction selector). Verify the directional end-stop indicator before admitting starting air.
- Return to remote control is prohibited while the engine is running. If electronic systems are restored, stop the engine fully, re-engage the fuel lever into the REMOTE position, and verify governor actuator position matches the fuel rack before re-starting.
Q2: Describe the operating principle of a shaft-mounted strain-gauge torsionmeter. How does it measure torque, and how is the signal extracted from the rotating shaft?
Model Engineering Answer:
Principle: When torque is transmitted through the intermediate shaft, the shaft experiences elastic torsional shear strain proportional to the applied torque (T = G × J × φ / L). Four metallic foil strain gauges are bonded to the shaft at ±45° to the axis, oriented along the principal shear strain directions, and connected in a Wheatstone full-bridge configuration.
Under torque, two gauges stretch (resistance increases) and two compress (resistance decreases), producing a differential voltage output directly proportional to torsional strain.
Signal Extraction: In older systems, carbon brush slip rings physically contact rotating copper rings on the shaft to carry excitation power in and the millivolt signal out. Modern systems use FM wireless telemetry: a miniature electronic module bonded to the shaft converts the bridge voltage into a frequency-modulated radio signal, transmitted contactlessly via a rotating antenna to a stationary receiver coil mounted adjacent to the shaft. This eliminates brush wear, contact resistance noise, and maintenance.
Power Computation: Shaft RPM is simultaneously measured by a proximity sensor counting teeth on the shaft flange. Brake power is then: Pb = 2π × N × T / 60.
Q3: What is the function of the slow-turning air valve on a main engine, and under what circumstances does it operate?
Model Engineering Answer:
The slow-turning valve protects the engine against hydraulic lock when restarting after an extended stop period (typically > 30 minutes).
During periods when the engine is stationary, liquid water (from a cracked liner or leaking exhaust valve cooling jacket) or liquid fuel (from a dripping injector) may accumulate on a piston crown. If the engine is started at full 30-bar air pressure, the piston would slam into the incompressible liquid column near TDC, catastrophically bending connecting rods or blowing off cylinder heads.
Function: When the propulsion control system detects that the engine has been stopped for more than 30 minutes, it automatically activates the slow-turning sequence before the normal start. Starting air is diverted through a pressure-reducing bypass valve, admitting air at only 8 to 12 bar. The engine rotates at 1 to 3 RPM for one complete revolution. At this reduced pressure, if the piston encounters a liquid obstruction, the shaft simply stalls rather than causing destruction. If the revolution completes successfully, the system automatically transitions to full 30-bar starting air and the normal start sequence.
Q4: What are the advantages of computer-based indicator systems over traditional mechanical spring-loaded indicators?
Model Engineering Answer:
Computer-based indicator systems offer decisive advantages:
- Speed Independence: Mechanical indicators suffer from inertia distortion above ~120 RPM. Piezoelectric sensors have no moving mass, accurately measuring at any engine speed from 0 to over 1,000 RPM.
- Crank Angle Synchronization: An optical encoder provides exact crank angle reference, enabling pressure-angle (P-θ) draw cards that directly reveal injection timing, ignition delay, and rate of pressure rise (dP/dθ). Mechanical indicators cannot produce crank angle referenced diagrams.
- Multi-Cylinder Overlay: All cylinders can be plotted simultaneously in distinct colors on a single screen. The weak or abnormal cylinder is immediately visible without comparing separate paper cards by eye.
- Digital Storage & Trending: Every card is stored digitally with date-time stamps, enabling comparison of current performance against sea trial baseline data and tracking degradation over thousands of running hours.
- Automatic MIP Calculation: Numerical integration automatically computes Mean Indicated Pressure, eliminating manual planimeter errors.
- Safety: The transducer threads permanently onto the indicator cock, eliminating the risk of hot pressurized gas venting at the operator during mechanical indicator handling.
Q5: Explain the significance of the characteristic pressure dip seen immediately after TDC on the draw card of an MC-type two-stroke engine. Should the engineer attempt to eliminate it by advancing fuel injection timing?
Model Engineering Answer:
The pressure dip after TDC on MC-type (camshaft-controlled) engines is a deliberate design feature, not a combustion deficiency. MAN B&W engineers intentionally retard fuel injection timing on MC engines to cap peak firing pressure (Pmax) approximately 35 to 55 bar below the theoretical maximum.
Engineering Reason: The crosshead bearing in a two-stroke crosshead engine does not rotate — it oscillates in a reciprocating arc. Unlike the crankpin journal bearing (which generates a full hydrodynamic oil wedge through continuous rotation), the crosshead bearing relies solely on squeeze-film lubrication. Excessive peak gas load crushes the oil film, causing metal-to-metal contact and bearing wipe. Limiting Pmax protects the crosshead bearing within its squeeze-film capacity.
The engineer must NOT advance injection timing to eliminate the dip. Doing so would increase Pmax beyond the crosshead bearing's load capacity, risking bearing failure. If engine performance is declining, investigate: scavenge air supply cleanliness, charge air cooler ΔP, piston ring condition, exhaust valve sealing, and cylinder liner calibration — not injection timing.
Standards & sources referenced
- SOLAS: International standards for the safety of life at sea.
- Conventions index
Found a mistake, or something unclear?
Report it in a few seconds — it goes straight to the editors.